
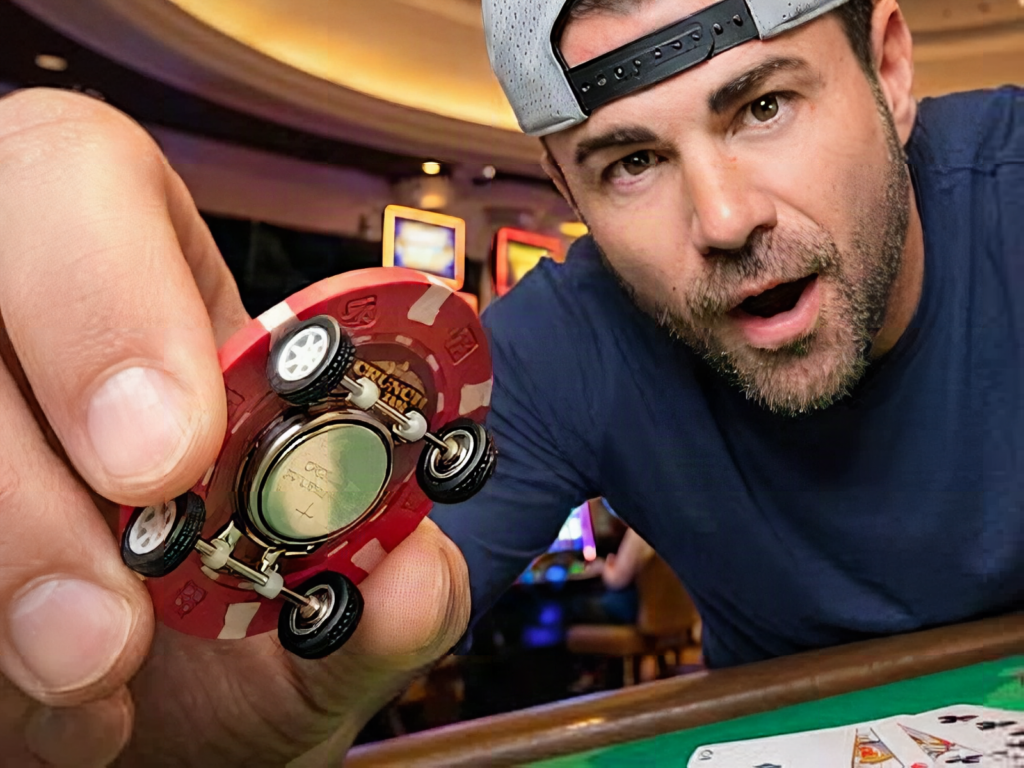
A poker chip that drives itself across a roulette table sounds like a prop from a heist film. Kevin Coda actually built one. He hollowed out a standard chip, packed in four miniature vibration motors fitted with rubber wheels, a custom PCB, an RF receiver and a coin cell, then walked it to a better number after the wheel had already stopped.
The chip was one entry in Mark Rober’s CrunchLabs Casino challenge, where makers were invited to beat classic casino games with hardware. Cheating was allowed. Getting caught was not. The result shows how much you can hide inside an everyday object with a soldering iron and a free weekend.
The builds worth studying
- Dice that change their minds. Dora from StrelkoMania suspended a steel ball bearing in low-melting-point wax inside each die. Silicone heating pads rated at 10 watts, sewn into her gloves, softened the wax long enough for the bearing to slide, then it cooled and locked the bias somewhere new.
- A wearable card counter. Christina Ernst hid the whole circuit in a garter. Concealed switches fed each dealt card to a microcontroller, which held the running count and blinked hidden LEDs with the statistically correct move.
- Computer vision up a sleeve. Tom from Tom Builds Stuff tucked a pinhole camera into his cuff, filmed the edge of the deck during the cut, and let software rebuild the card order.
- Zero electronics. Nate Scovill renumbered two dice, one carrying 1, 2 and 3 twice over, the other 4, 5 and 6, deleting every extreme total from the odds table.
What is actually going on in there
Strip the theme away and these are ordinary embedded problems. The robot poker chip is a differential drive with no room for a proper motor driver IC, so small vibration motors switched through MOSFETs do the job, and a 2.4 GHz link of the sort you get from an nRF24L01+ paired with an ATtiny or an ESP32-C3 covers the remote control. The loaded dice are a thermal control loop: hobby wax softens around 55 to 60 °C, a pad pulling roughly 1 A at 5 V gets there in seconds, and the bearing must set before the next roll. The card counter is the gentlest of the three, since a Hi-Lo running count is a few additions and a handful of GPIO pins for switches and indicator LEDs.
Build it yourself
Start with the card counter if you want something working this week. A Seeed XIAO or a Pro Micro, five tactile switches on separate GPIO pins with the internal pull-ups turned on, and three LEDs for hit, stand and double give you a complete circuit on a breadboard. The gotcha is debounce: hand-wired switches will register two or three presses per tap and wreck the count, so either drop a 100 nF capacitor across each switch or hold a 20 ms software lockout after every edge. Watch the original write-up at Hackster and pick one technique to steal for your own build.
Frequently Asked Questions
How does the remote-controlled poker chip move on its own?
Four miniature vibration motors fitted with rubber wheels sit inside a hollowed-out chip alongside a custom PCB, an RF receiver and a coin cell. Switching the motors in pairs steers it, the same way a differential-drive robot turns, and the radio link lets the operator nudge it across the table.
What skills and parts would I need to attempt one of these builds?
The card counter is the realistic starting point: a small board such as a Seeed XIAO or Pro Micro, five tactile switches, three LEDs and a battery. You need basic soldering, comfort reading a pinout, and enough firmware to debounce inputs and keep a running count. The chip robot is much harder because everything must fit in a few millimetres of height.
What will I learn if I build this?
You practise the core embedded skills all at once: reading GPIO inputs cleanly with pull-ups and debounce, driving small motors and LEDs without overloading a pin, budgeting current from a coin cell, and packaging a circuit into a space that was never meant to hold one. Those same constraints show up in thesis projects, robotics competitions and any wearable build.
