
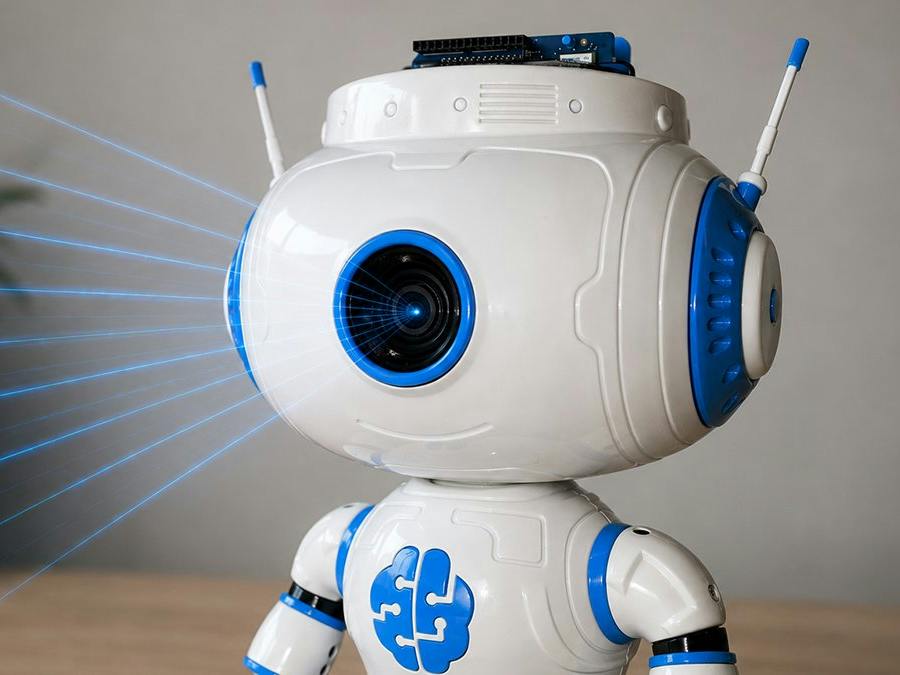
Block off one Saturday and you can have a desk robot that waves, beeps, and recognizes parts on your bench. JBR-001 is an open source build around the Arduino UNO Q: three servos, a USB camera, a distance sensor, a buzzer, and a small animated display.
What the builder made
The head turns on one servo, and two more servos swing the arms. A camera in the head plugs into the UNO Q through a USB-C hub. At the back of the head sits a Modulino Distance sensor, so the robot notices when someone walks up. The Modulino Buzzer plays short note sequences, and the display swaps faces to match the mood.
The fun part is the vision model. The creator trained it to spot different Arduino Modulino boards, using a synthetic dataset with varied angles, backgrounds, and lighting, then ran the training in Edge Impulse. Show it one board and it turns its head and raises an arm. Show it another and it plays a different tune.
Parts and cost reality
- Brain: Arduino UNO Q (Linux side runs the vision model, the MCU side drives the servos)
- Motion: 3 hobby servos on a separate 5 V supply, not the UNO Q rail
- Senses: USB camera, Modulino Distance over Qwiic (I2C, SDA and SCL)
- Output: Modulino Buzzer plus a small display
The gotcha is power. Three servos stalling can pull well over 1 A, which will brown out the board if they share its supply. Give them their own 5 V source and tie the grounds together. The body is printed, but any small enclosure works if you do not have a printer.
Spend your Sunday on this
Saturday, wire the servos and get the head and arm sweep working with a plain Servo library sketch. Sunday, train a tiny Edge Impulse model on three objects from your own desk, like a resistor, an LED, and a jumper wire, and map each one to a different arm move. Swapping the model never touches the hardware, which makes it a good classroom or thesis starter for edge AI.
Full write-up and files are on the Hackster article. Servos and distance sensors for the practice rig are in stock at circuit.rocks, starting around PHP 60 for a 9 g servo.
Frequently Asked Questions
How does JBR-001 recognize objects?
A USB camera feeds images to a vision model trained in Edge Impulse and running on the Arduino UNO Q. The demo model identifies Arduino Modulino boards, and each detection triggers its own head, arm, display, and sound reaction.
What parts and skills does this build need?
You need an Arduino UNO Q, three servos with a separate 5 V supply, a USB camera and hub, a Modulino Distance sensor, a buzzer, and a display. Basic wiring, I2C, and servo control are enough to start; the vision model is trained through a web tool.
What will I learn if I build this?
You will practice servo control and power isolation, I2C sensor reading, and the full edge AI loop: collect or synthesize images, train a model, deploy it, and tie detections to hardware. That fits a robotics class or a capstone project.
