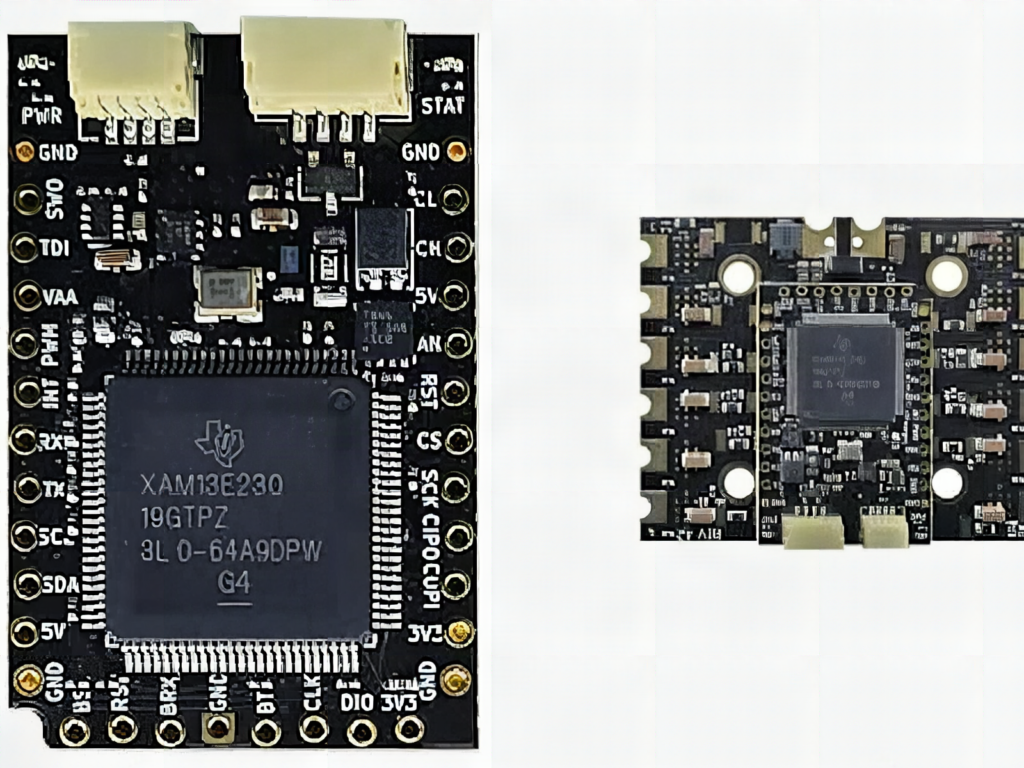
How do you drive four brushless motors from one board without wiring up four separate controllers? BeagleBoard answers with two open source boards, the BeagleConnect Torque module and the BeagleConnect QuadESC, described in this Hackster.io report.
What the two boards do
The Torque module is the brain. It is built around a Texas Instruments AM13E23019 microcontroller with a 200 MHz Arm Cortex-M33 core, 512 KB of flash and 128 KB of SRAM. A trigonometric math unit speeds up motor control calculations, and a TinyEngine neural accelerator can handle jobs like fault detection. The QuadESC board carries that module plus four independent three-phase drivers, each with a TI DRV8323SRTAR gate driver, so one controller can spin four brushless DC motors at once.
The technical answer
Each motor channel reports three-phase current, three-phase voltage and temperature, and the board also watches battery voltage. That feedback is what field-oriented control needs to regulate torque and speed. Power comes from a 3S to 6S pack, anywhere from 9 V to 25.2 V, with 40 A continuous and 70 A burst per motor. For talking to the rest of your robot there are CAN FD, UART, SPI and I2C, plus a Qwiic connector for sensors and two 12-pin headers. A gotcha for students: this is a developer board, so you write the firmware yourself, and field-oriented control is not included out of the box. Pricing and availability are not announced yet, so treat it as a design reference for now. If your team builds a quadcopter or a four-wheel rover for a school competition, this is the kind of board that replaces a tangle of four hobby ESCs and a separate flight controller.
Try it
You do not need a 25 V drone-class setup to practice the ideas. Start on a breadboard with a small brushless motor, a simple ESC and a library such as SimpleFOC on an ESP32, and log current against speed. When your team outgrows that, read the KiCad schematics BeagleBoard has published to see how a real gate driver is laid out. Browse the motor drivers and microcontroller boards at circuit.rocks for a low-cost starting point, and follow the source article for launch news.
Frequently Asked Questions
How many motors can the BeagleConnect QuadESC control?
Four brushless DC motors, each with its own three-phase driver using a TI DRV8323SRTAR gate driver and three CSD88599Q5DC half-bridge devices, with independent PWM resources.
What power and firmware does it need?
A 3S to 6S battery supplying 9 V to 25.2 V, rated 40 A continuous and 70 A burst per motor. You must write your own firmware, since field-oriented control and AI diagnostics are not preloaded.
What will I learn if I build this?
You practice three-phase motor drive, current and voltage sensing, field-oriented control, CAN FD networking and reading open KiCad schematics, all useful for ECE thesis and robotics competition work.
