
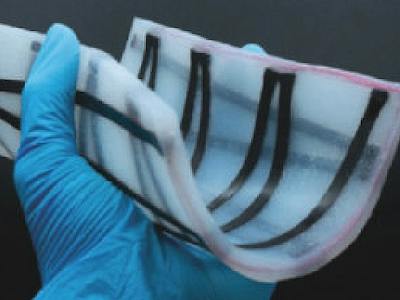
A physical therapist can watch your arm move, but a sheet of silicone that reports its own shape could log every degree of that motion between visits. MIT mechanical engineers built exactly that, and the trick is cheap enough to copy on a bench, as Hackster’s write-up explains.
What the MIT team built
Qufan Yu and colleagues embedded several rubber waveguides in a soft silicone sheet. Each waveguide has a clear core inside a black outer layer, and one side of the core is deliberately roughened. Bend a fiber and less light reaches the far end. Because only one side is rough, the loss also changes depending on whether the fiber curls toward or away from that side, so a single strand tells you bend direction, not just bend amount.
Combine a grid of those strands and software can rebuild the 3D surface. The team reports a reconstruction error under 0.4 cm, compared with roughly 1 to 2 cm for older designs that use rigid sensors. The work appears in the open-access journal Advanced Intelligent Systems.
Why the readout is easy to reproduce
- Each strand needs one LED at one end and one light detector at the other.
- A phototransistor into an ESP32 ADC pin gives 12-bit readings (0 to 4095) at a few hundred samples per second.
- Calibrate by logging the raw value flat, then at 30, 60, and 90 degree bends.
- The gotcha: ambient light leaks in through thin spots, so wrap the sensor in black heat-shrink or opaque tape.
Build it yourself
Skip the custom rubber and start with a 1 mm plastic optical fiber, a 5 mm red LED with a 220 ohm resistor, and a phototransistor on a breadboard. Scuff one side of the fiber with 400-grit sandpaper to mimic the rough core. Run the LED from 3.3 V, read the detector on GPIO34, and plot the value as you bend the fiber each way. Two strands crossed over a foam sheet already give you a crude two-axis surface sensor, a decent thesis seed for a wearable rehab band or a soft robot gripper. ESP32 boards and sensor modules are listed at circuit.rocks, and the research summary is at the Hackster source page.
Frequently Asked Questions
How does the MIT sensor detect bend direction?
One side of each rubber waveguide core is roughened, so light loss changes depending on whether the fiber bends toward or away from the rough side. A single strand reports both bend amount and direction.
What parts do I need to test the idea at home?
A plastic optical fiber, a 5 mm LED with a 220 ohm resistor, a phototransistor, and an ESP32 or Arduino with an ADC pin. Black tape blocks stray light. Total cost is a few hundred pesos.
What will I learn if I build this?
You will practice analog sensing with an ADC, calibration against known angles, noise and ambient light rejection, and turning raw readings into a shape estimate, all useful for wearable and soft robotics thesis work.
