
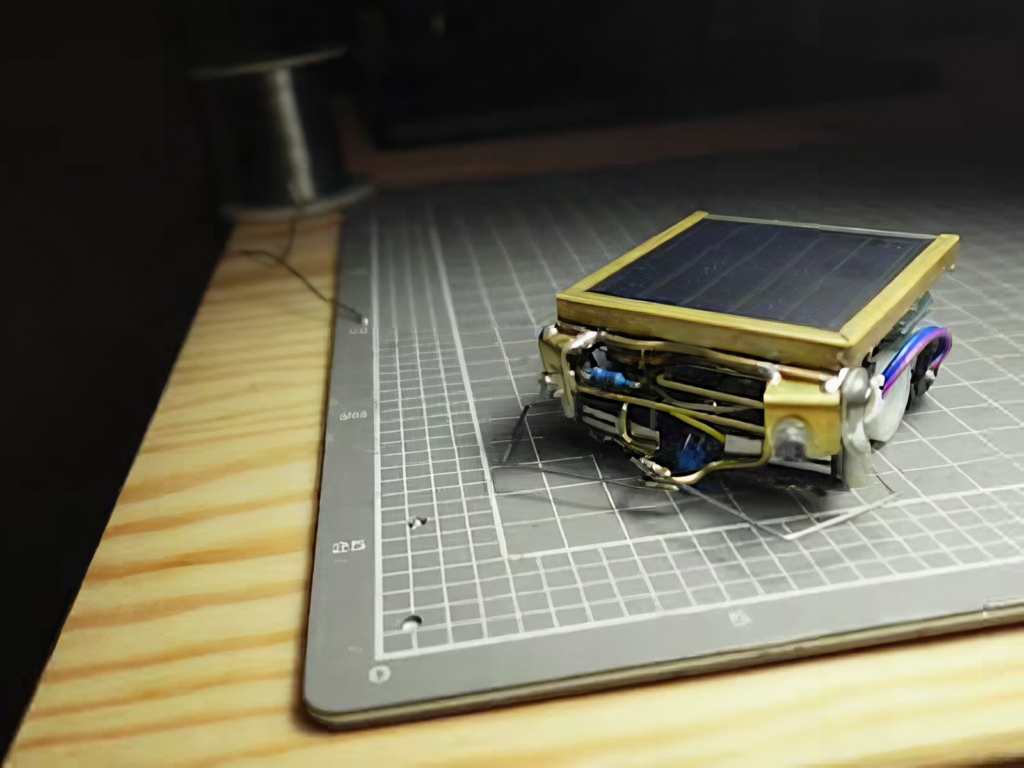
Most student robots start with an Arduino sketch and a motor driver board. A smaller camp of makers goes the other way and builds robots that think with transistors and inverter chips instead. It is called BEAM robotics (Biology, Electronics, Aesthetics, Mechanics), and YouTuber ALTco just added a charming entry: a battery-free, solar-powered pet that wanders the living room with zero lines of code. Hackster News covered the build.
The build itself
Two N20 gear motors drive a pair of wheels with rubber O-rings pressed into grooves for grip. A solar cell sits on a brass frame on top. Instead of a battery, a Miller solar engine stores harvested energy in a capacitor and releases it only when enough charge has built up, so the pet moves in bursts that look oddly like hesitation. Two photodiodes act as eyes. In bright light the robot heads toward the source, and in dim or uneven light it wanders.
Technical takeaway
The brain is two coupled oscillators. One sets motor activity, the other is nudged by the photodiodes and shifts speed and direction. Two stacked 74HC240 inverter chips drive the motors, chosen because their standby current is tiny, which matters when your only supply is a small solar panel. When the oscillators drift out of phase in patchy light, you get the unpredictable, animal-like path with no algorithm behind it. The gotcha for first-timers: a Miller engine needs a capacitor sized for your panel, so expect to swap values several times. ALTco used sockets for the resistors and capacitors for exactly that reason.
What to try next
Skip the microcontroller for one weekend. Order a few 74HC240 or 74HC14 chips (a handful costs under PHP 100 at Circuit.Rocks), two N20 motors, a small solar cell, and a pair of photodiodes. Breadboard one oscillator first and watch it on an LED before wiring the motors. Then compare the result with an Arduino line follower: the analog pet reacts in microseconds but cannot be reprogrammed, which makes a great talking point for a robotics class or competition write-up. Read ALTco’s original build notes via the Hackster article for the full part list.
Frequently Asked Questions
How does this robot steer without a microcontroller?
Two photodiodes feed a pair of coupled oscillators built around 74HC240 inverter chips. The light level shifts the oscillator phase, which changes the speed and direction of the two N20 motors.
What parts and skills does a BEAM build need?
You need two N20 gear motors, 74HC240 chips, a small solar cell, a capacitor for the Miller solar engine, two photodiodes, and basic soldering. Expect to tune capacitor values by trial.
What will I learn if I build this?
You will learn how oscillators, capacitors and inverter logic can produce behavior, how solar energy storage works, and how analog circuits compare with programmed control in robotics.
